Tool Radius Compensation

Digital Manufacturing
Paolo Bosetti

Università di Trento, Dipartimento di Ingegneria Industriale

Updated: 19/10/2026

Tool radius compensation (TRC)

A possible feature to implement for the personal project

TRC and G-code

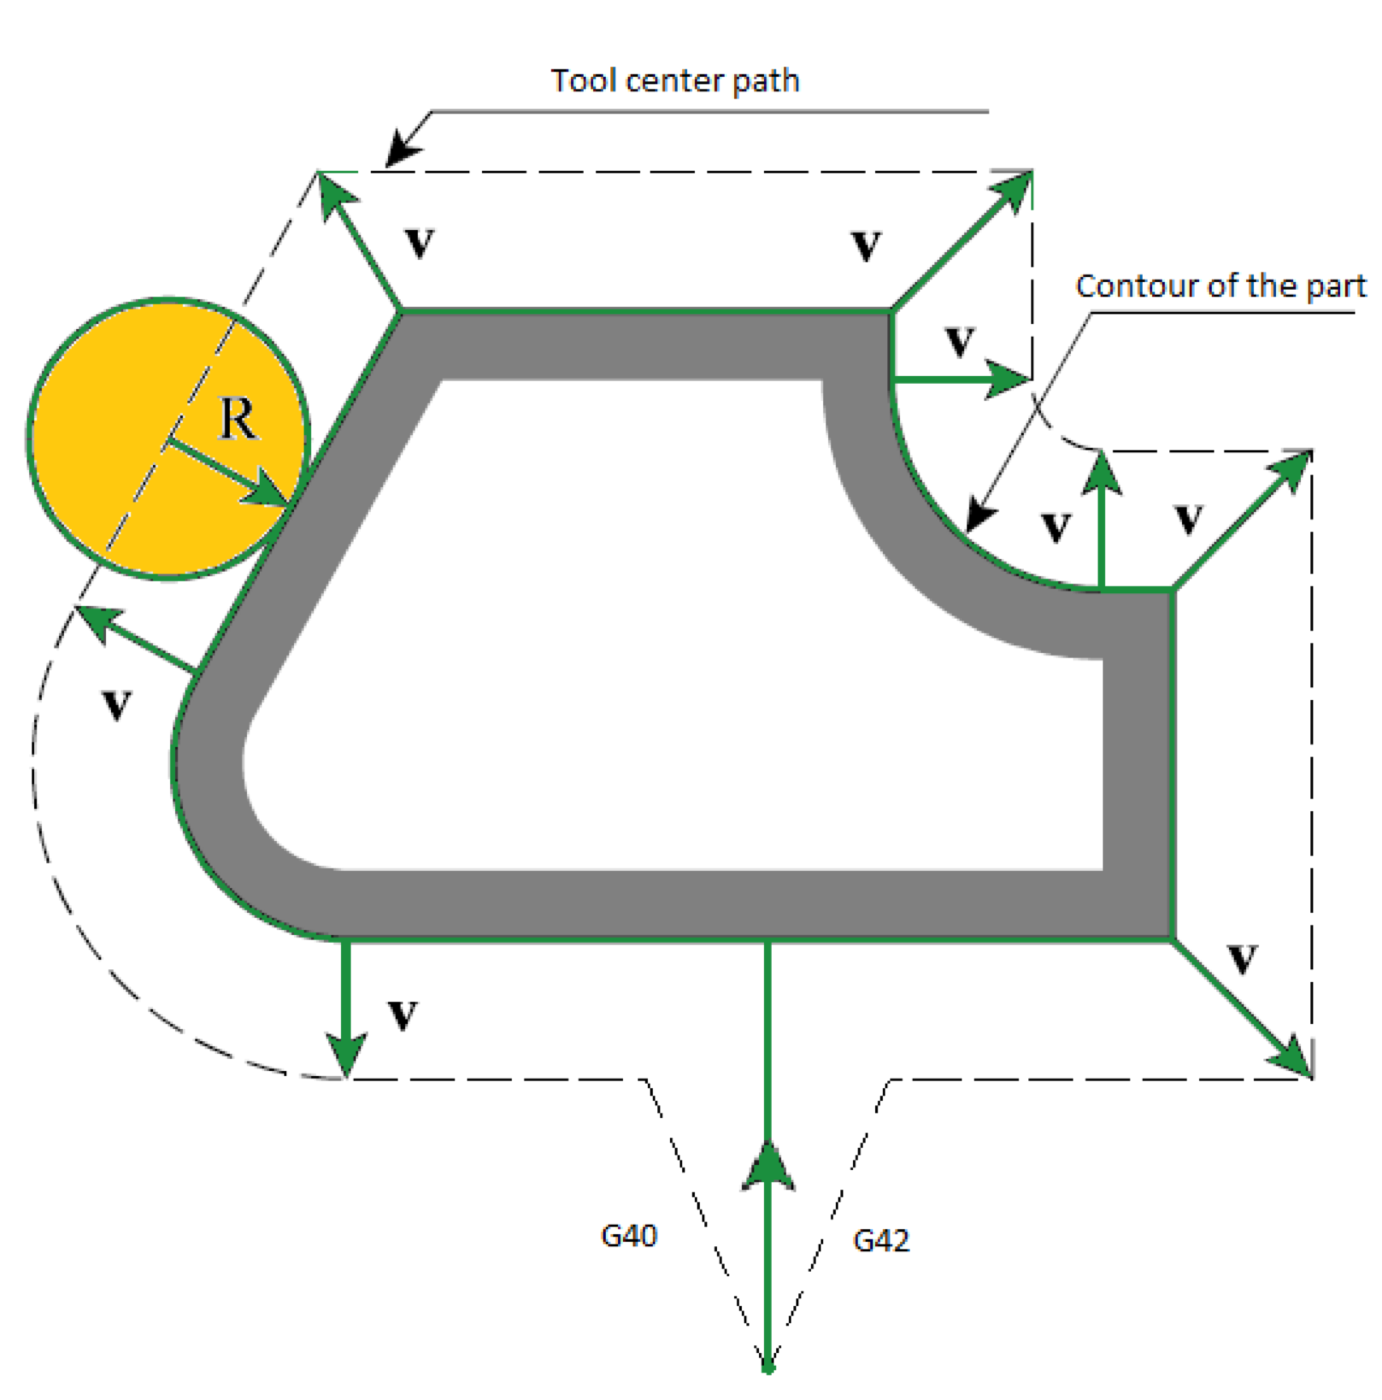
  • G-code standard supports a feature for offsetting the tool trajectory to the left or to the right of the trajectory by an amount equal to the tool radius
  • This is only affecting the X-Y projection of the trajectory, Z values remain unchanged
  • The TRC is set to the left with G41, to the right with G42 and is disabled with G40
  • TRC is fully active at the end of the current block

Tool radius compensation

  • TRC offsets the tool center path (programmed points) according to G41/G42
  • New target points are calculated for each block on the basis of the offset intersection with the next block (arc or line)
  • Disabled for rapid motions

Tool radius compensation: Line-Line

Tool radius compensation: Line-Circle

Line-Line case

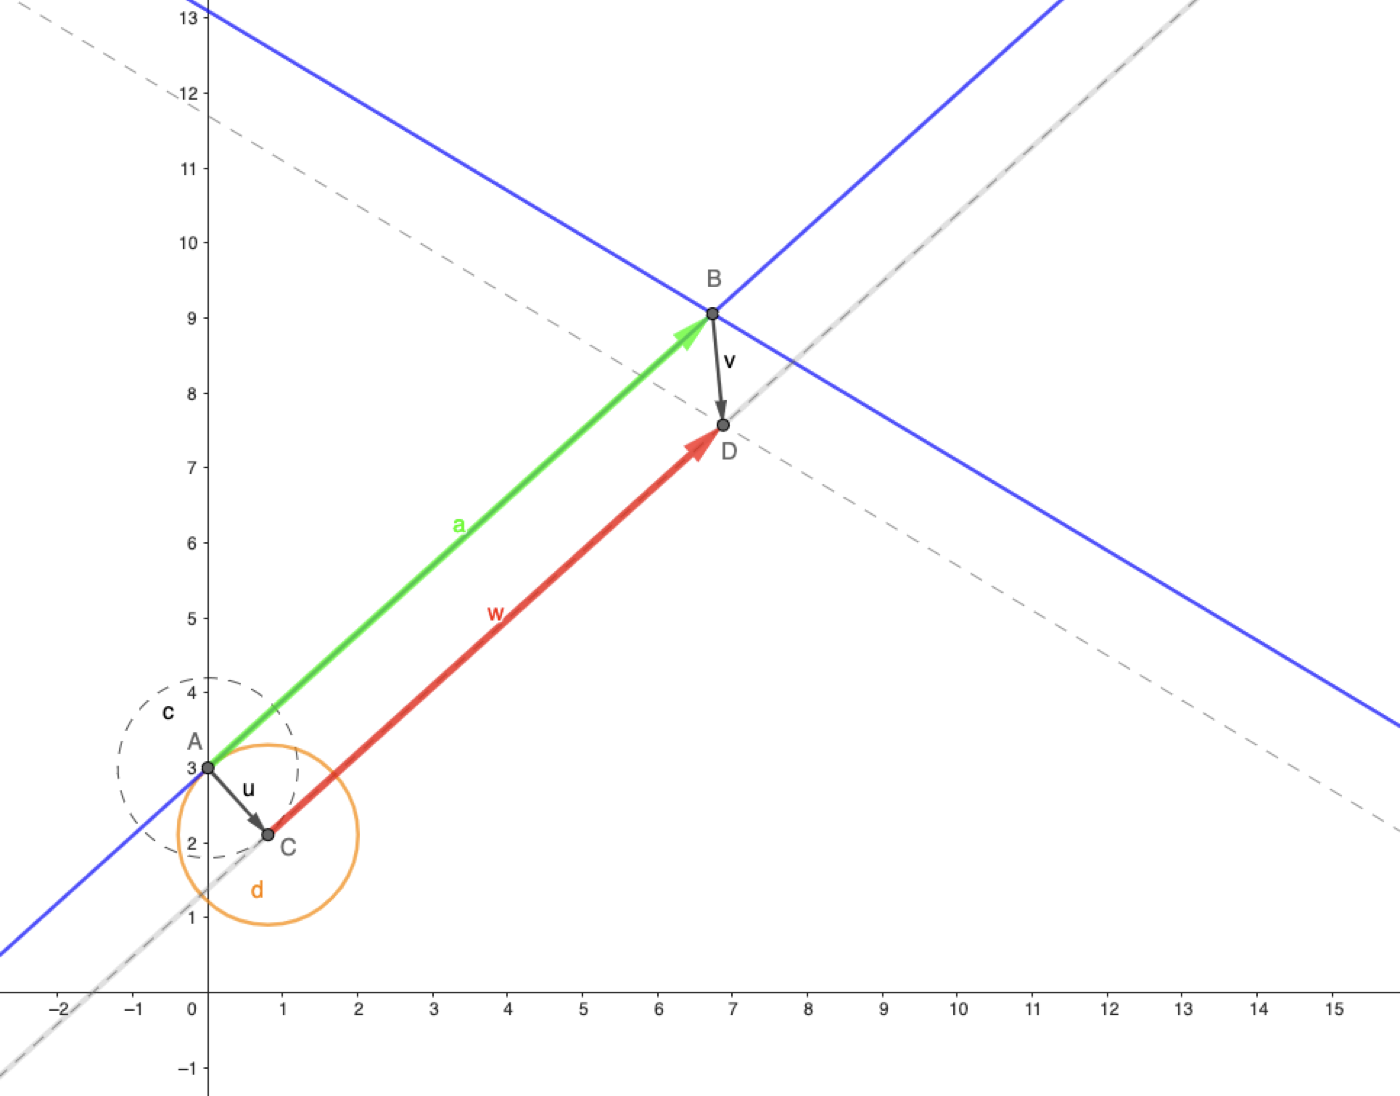
We need to calculate the point \(D\):

  1. Given the line equation \(y = ax + b\), we need to calculate the equation of the offset line(s)
  2. Calculate \(D\) as intercept between the two offset lines
Line-Line case

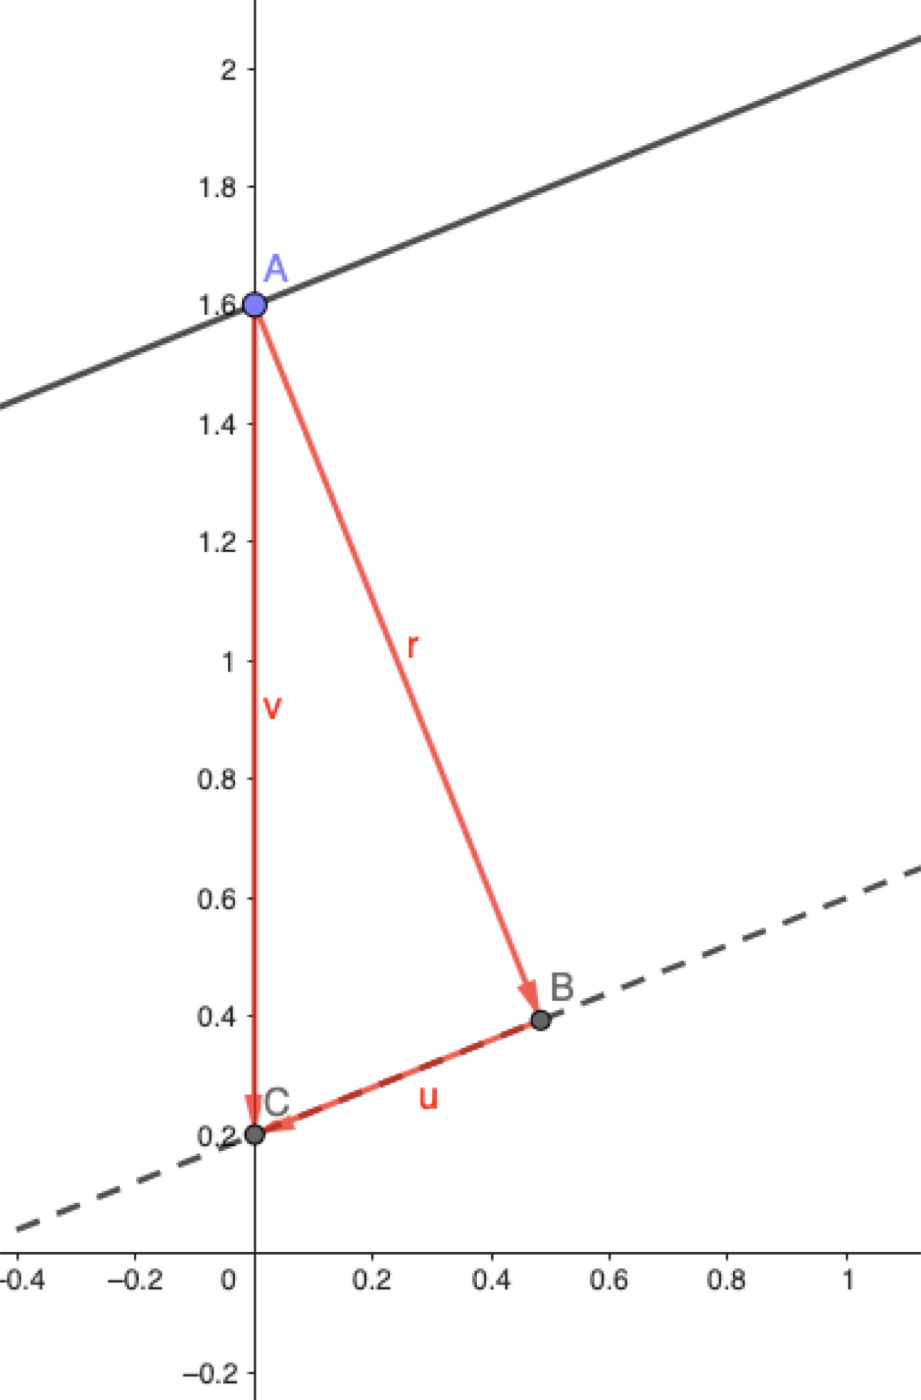
  • Given \(y = ax + b\), the equation of the offset line is \(y = ax + b - v\)
  • Being \(a = u/r\), it follows that: \(v = \sqrt{u^2 + r^2} = r\sqrt{a^2 + 1}\)
  • So, \(y = ax + b \pm r\sqrt{a^2 + 1}\)
  • The sign depends on G41/G42 and on the path direction
Line-Line case

Intersection \(D\) between

\(y = a_1 x + b_1 - v_1 = a_1 x + b_{o,1}\)

and

\(y = a_2 x + b_2 - v_2 = a_2 x + b_{o,2}\)

has coordinates:

\[(x_i, y_i) = \left(\frac{b_{o,2} - b_{o,1}}{a_1 - a_2}, \frac{b_{o,1}a_2 - b_{o,2}a_1}{a_2 - a_1}\right)\]

Line-Line case

  • Exception: when two segments are collinear (\(a = a_1 = a_2\)), the intercept is undefined
  • The new intersection node is set at an offset \(r\) perpendicular to the segments

\[C = \begin{cases} (0, -r), & \text{when } a = 0 \\ r(s, -s/a) \text{ with } s = \frac{a}{|a|}\sqrt{\frac{a^2}{1 + a^2}}, & \text{otherwise} \end{cases}\]

Line-Arc (or Arc-Line)

Similar to line-line case, but with a caveat:

  • Line-circle intersection gives two points, \(G\) and \(B_r\): you have to select the intersection that is closer to the node to be offset (\(B\) in figure)
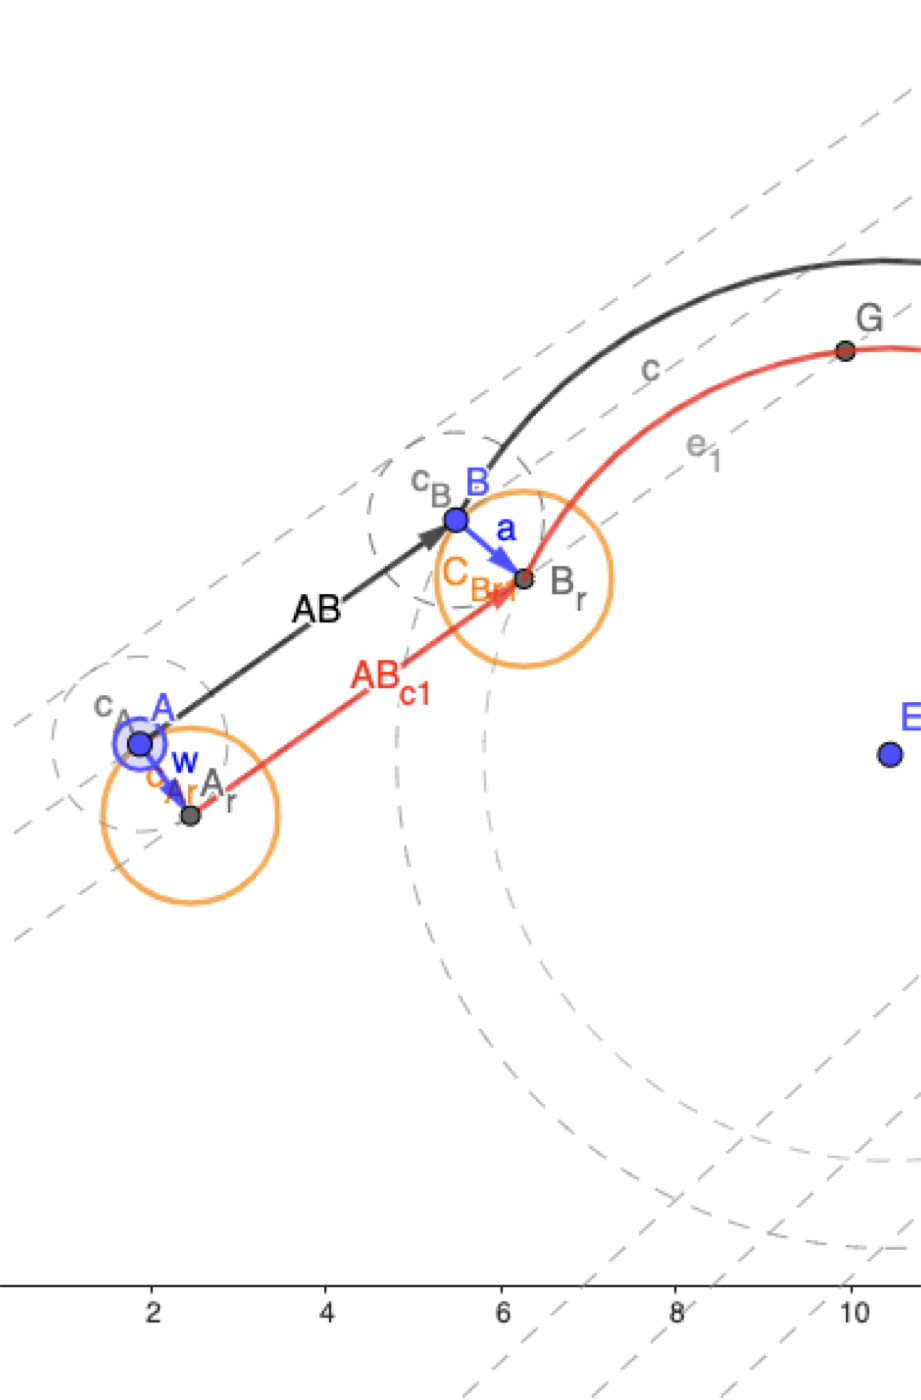
Non-tangent line-arc case

Line-Arc (or Arc-Line)

Similar to line-line case, but with a caveat:

  • Line-circle intersection gives two points, \(G\) and \(B_r\): you have to select the intersection that is closer to the node to be offset (\(B\) in figure)
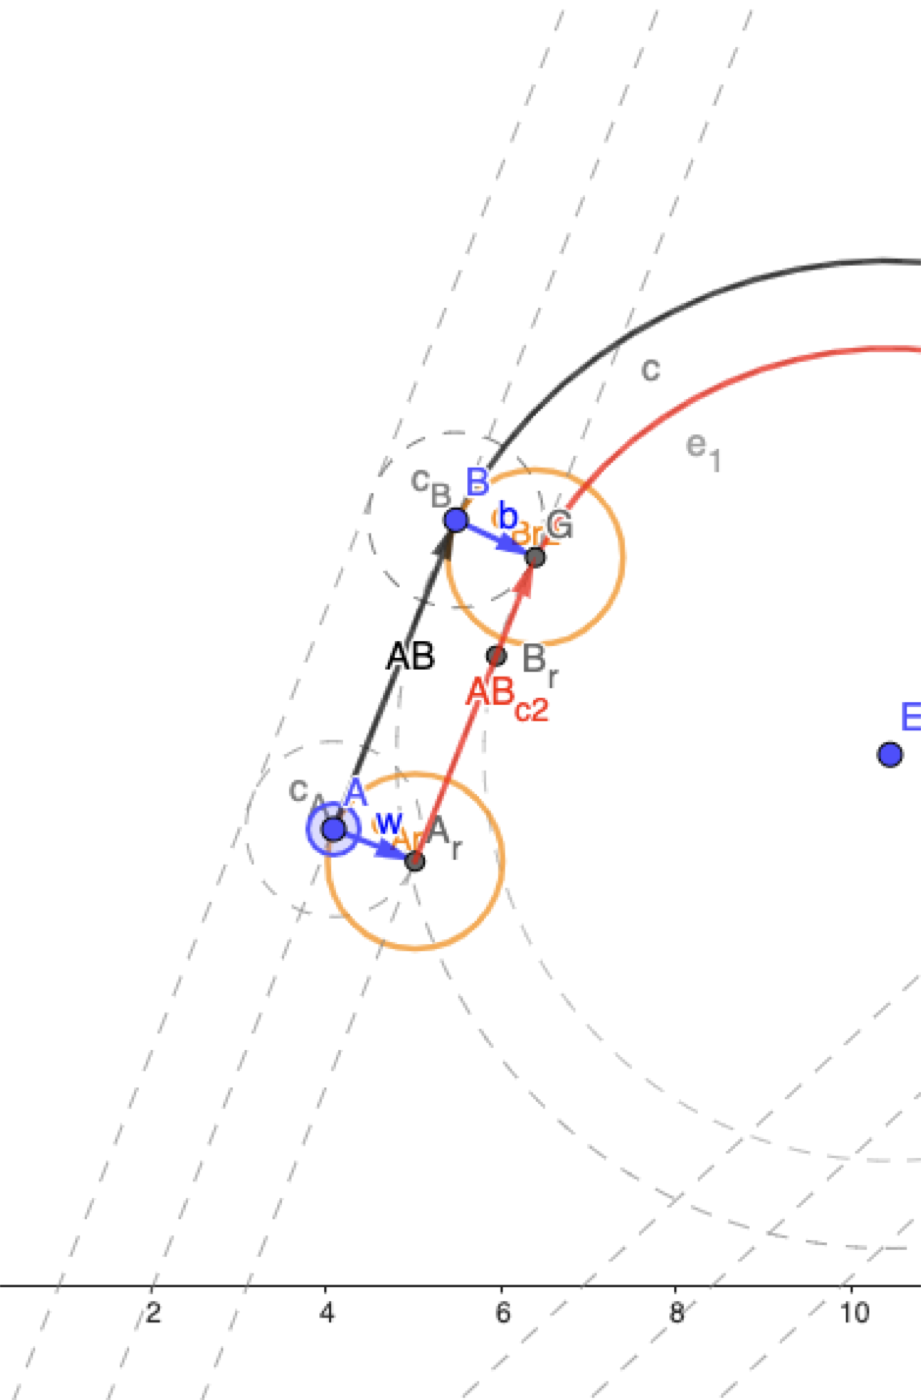
Tangent line-arc case

Code changes

Support for G40/G41/G42

  • An enum class TRCType with NONE, LEFT, RIGHT
  • An TRCType _trc field in the BlockTRC class
  • Proper code in BlockTRC::parse()
  • _trc shall be managed as a modal field (i.e. inherited from previous block)

Code changes

Support for tool radius

  • The YAML file needs to have a field as: tools: [10.0, 8.0, 5.0, 2.5] giving the list of available tools and respective radiuses
  • The Machine class needs to properly load the tool list into a new field: vector<data_t> _tools
  • Add machine::tool_radius(), which returns the radius of a given tool number

Code changes

Support for offset calculation

  • The method Block::parse() needs to change the target of the previous block if the previous block has _trc != TRCType::NONE
  • The target must be changed according to the equations shown above and the radius of the current tool

Code changes

Support for offset calculation

  • Equations for intersections possibly require:
    • Block::angle_with_prev(): angle in radians with previous block
    • Block::equation(): returns \(a\) and \(b\) as output parameters (refs); for an arc, parameters of the implicit equation \((x - x_c)^2 + (y - y_c)^2 = r^2\) are available already
  • These functions can be private

Advanced TRC

Rules

  • You must work alone (I’ll check and compare results!)
  • Document progress with commits published on GitHub (private repo shared with me)
  • No help from my side, except these slides
  • When you are done, you must discuss your work with me
    • If it works (no warnings, errors/errors, works as expected) and it is not copied, you get 30/30
  • If you implement advanced TRC or impress me with some other clever addition, you get 30/30 cum laude
  • Must be done before the end of next year